The robotic arm of the "Striver" deep-sea manned submersible can operate flexibly in high-pressure environments.
| Category | Earth & Ecology |
|---|---|
| Standard size | Custom size |
| Supply | Single unit or batch · OEM to your drawing |
| Lead time | Standard 4–8 weeks after deposit (confirmed per contract) |
| Warranty | 1 year, structure and control |
| Documents | Specification sheet · control diagram · spare-part list |
A standard catalogue model: the dimensions, control package and finish are fixed, which is what keeps the price and the lead time predictable. Size, colour and interface language can be adapted without a new design cycle.
Standard models from this range are also listed in our online store, priced in USD — see the price yourself ↗
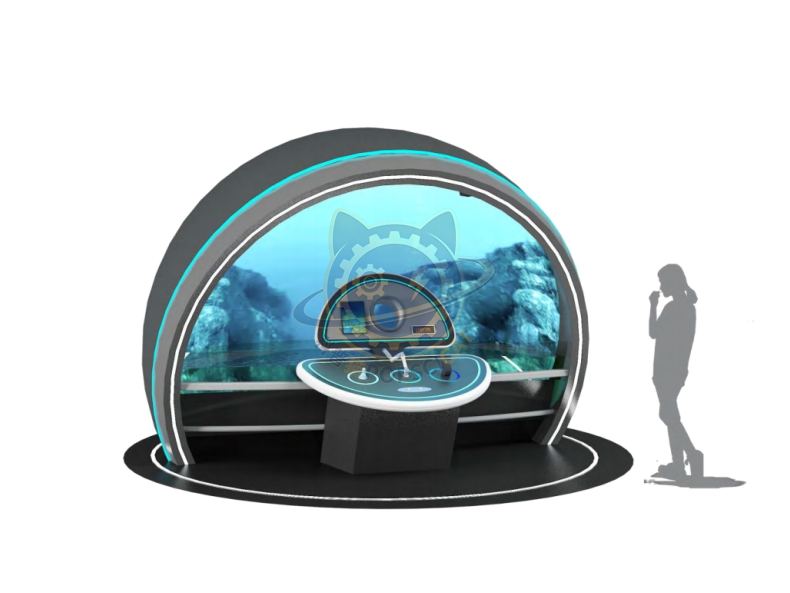
The robotic arm of the "Striver" deep-sea manned submersible can operate flexibly in high-pressure environments. This manipulator is developed by Shenyang Institute of Automation, Chinese Academy of Sciences. It has 7 joints, and can realize 6-DOF motion control. Its operating accuracy is up to 1cm, and it can bear more than 60kg. It can easily complete precise operations such as underwater placement and picking, filling the technical gap in the 10000 meter operation of Chinese hydraulic manipulators.
The unit is designed for unsupervised public use: controls are recessed or shielded, moving parts are enclosed, and the interface is operable by a child of about six with no instruction. Where a screen is used, the language can be switched without changing the hardware, and the content can be replaced on site.
The deep-sea robotic arm carried by the "Striver" is a typical multi degree of freedom electro-hydraulic servo drive operation system. Its core scientific principles integrate deep-sea pressure adaptation technology, multi degree of freedom motion control, hydraulic servo drive, and force feedback closed-loop control, which can complete high-precision underwater operations in extreme high-pressure environments at depths of tens of thousands of meters. In the deep-sea static pressure environment of about 110 megapascals, the robotic arm adopts a pressure resistant seal and pressure compensation design, which offsets the huge external water pressure through an oil filled balance structure, ensuring that the joints and drive mechanism can still move flexibly under high pressure. The system has six degrees of freedom of motion and relies on the coordinated control of servo motors and hydraulic actuators, combined with real-time signal feedback from the cabin control unit and underwater sensors, to form high-precision closed-loop control. The positioning accuracy of the operation can reach 2 centimeters. At the same time, the end effector of the robotic arm integrates functions such as clamping and sampling. Through force sensing and position adjustment, it can complete seabed sediment sampling and rock collection.
Every unit leaves the factory after a running test: mechanisms cycled, electronics burned in, edges dressed, fixings torqued and marked. Wear parts — bearings, sliders, lamps, belts, touch panels — are modular and listed on the spare-part sheet, so a venue technician can replace them without returning the exhibit. Crating is plywood with foam blocking; the loading plan and packing list travel with the shipment.
Other models from the Earth & Ecology line, all held to the same specification and the same control package.

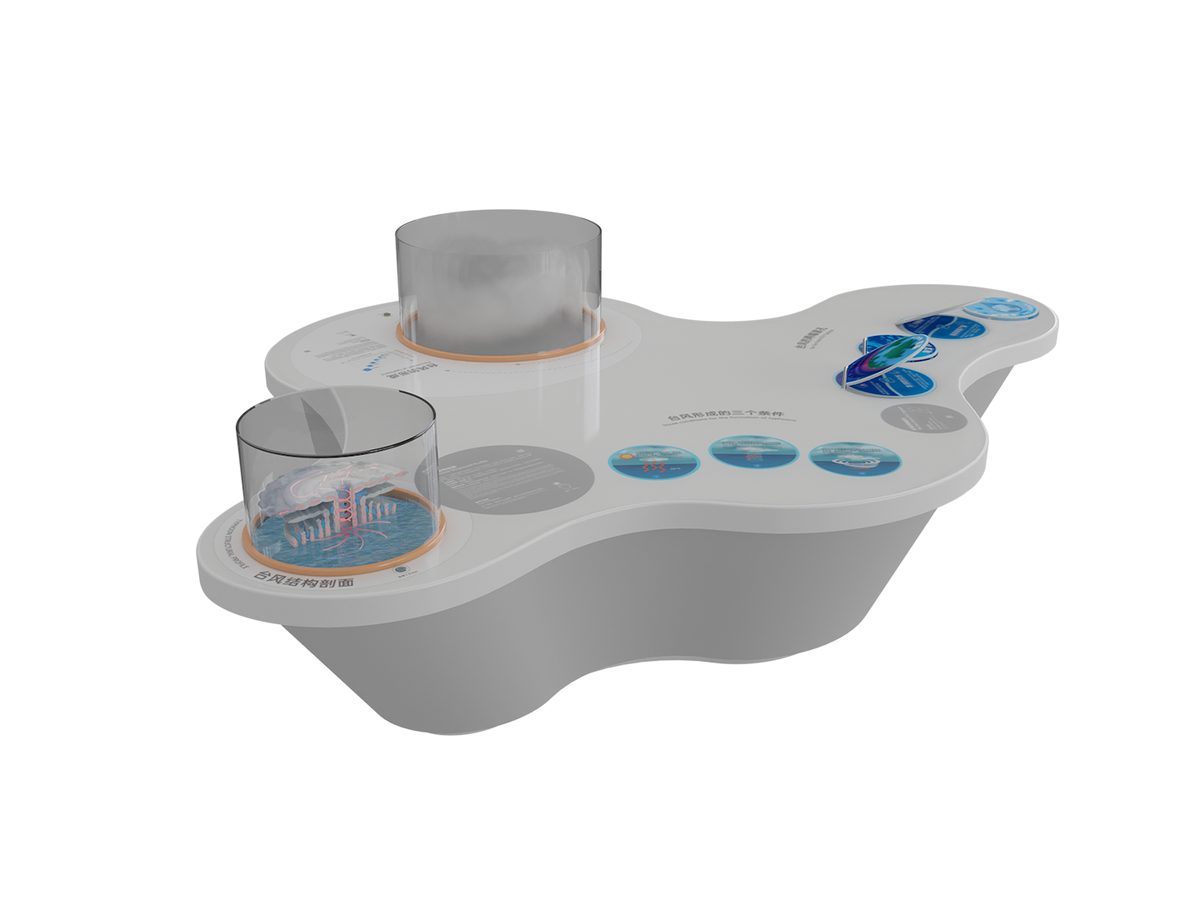
A vertical slice through a storm showing eye, eyewall and spiral bands.

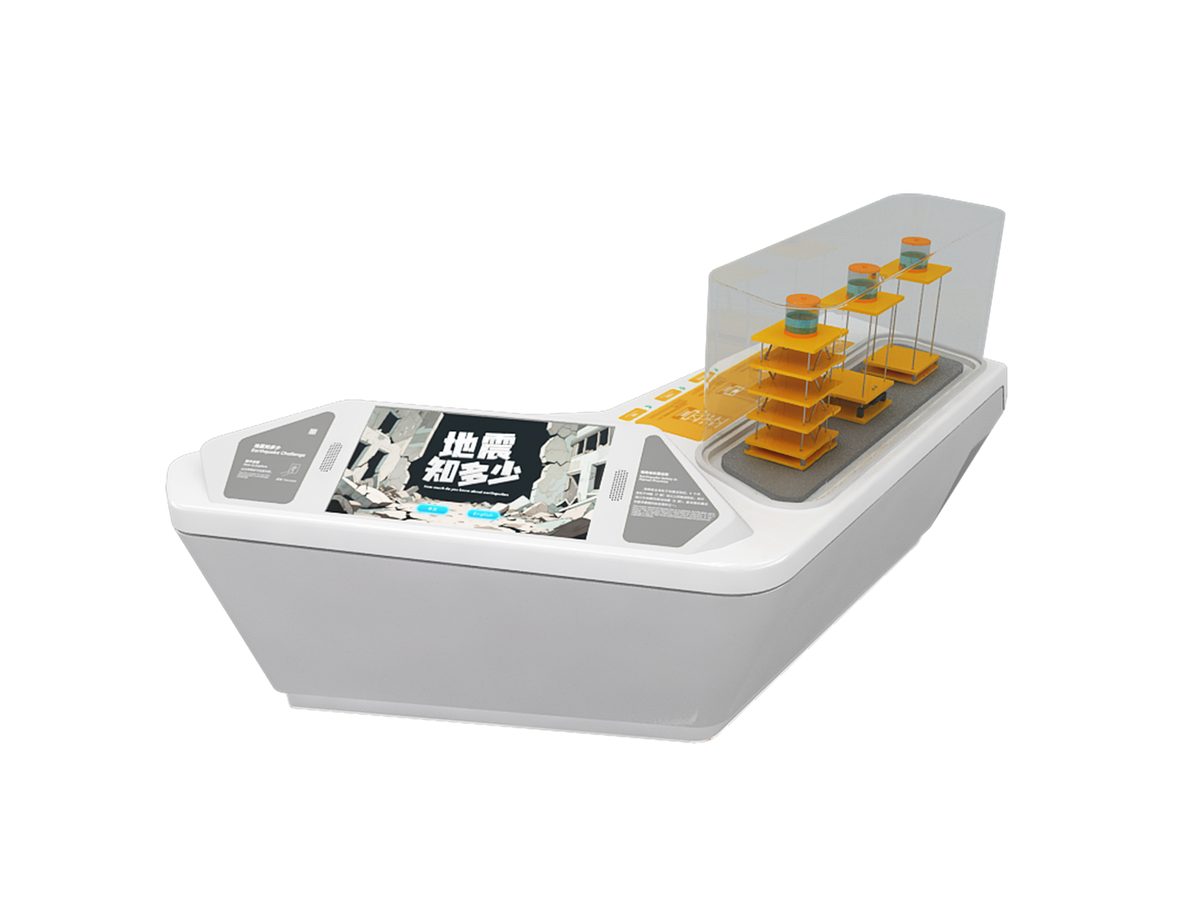
A platform shakes at recorded intensities while a seismograph traces the movement.

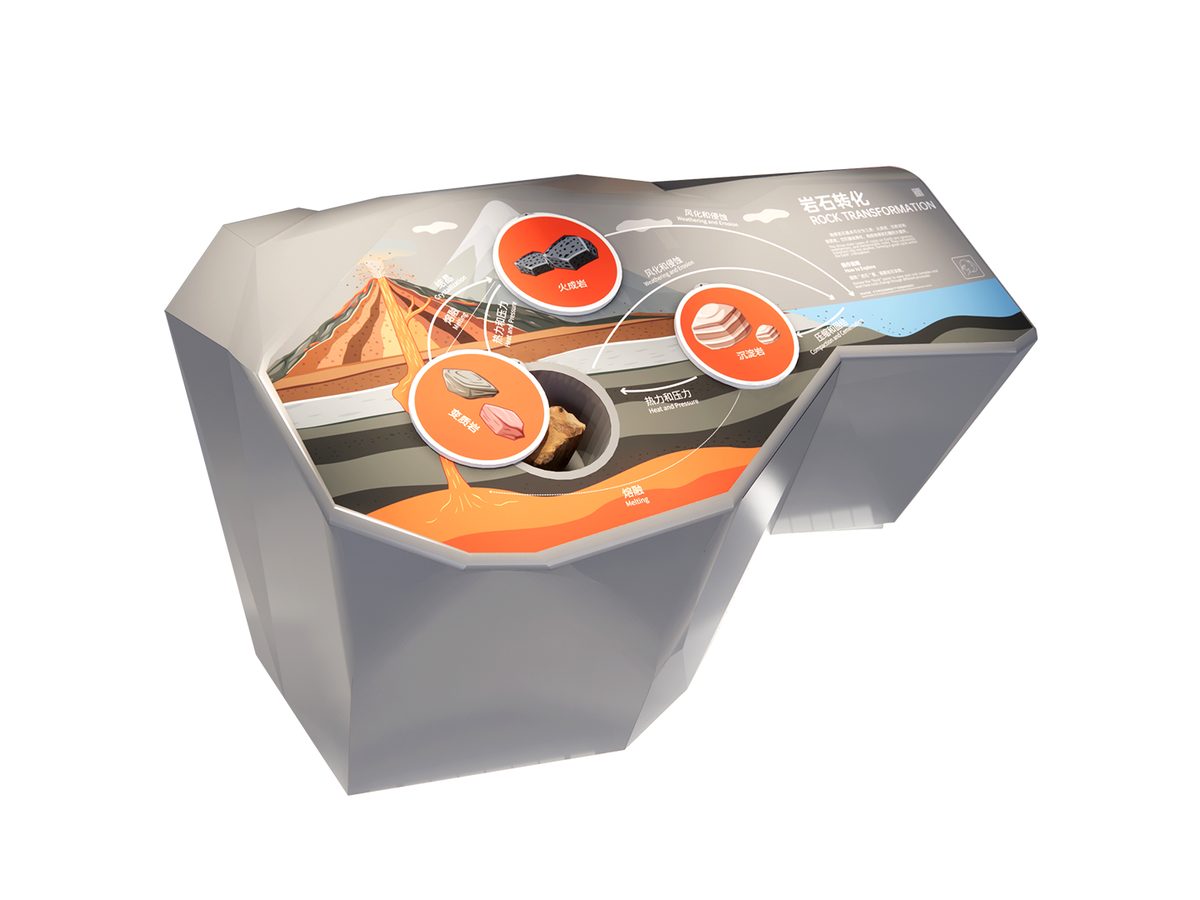
Heat and pressure turn one rock type into another on a turntable.

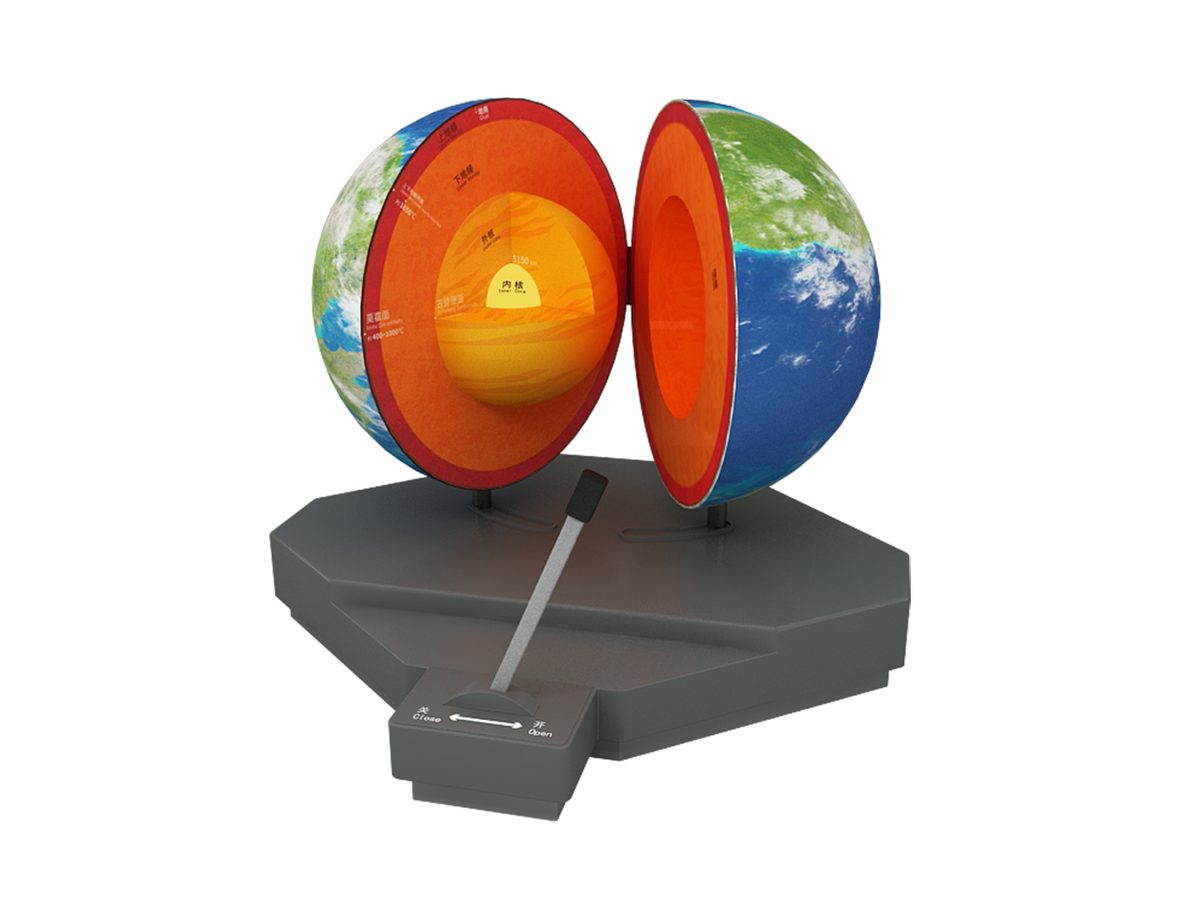
Cut-away globe showing crust, mantle, outer and inner core.
Attach a theme outline, a floor plan, or nothing at all — a photo of the space is enough to start. Quotations are issued against a real exhibit list, not per-square-metre guesses.
Scan to add us